Jacob Valdez
Data/ML Engineering, Robotics, Full-Stack
- Aug 2026 – Oct 2026Research Collaboration · TalOS Robotics
Robot learning and VLA research with the TalOS Robotics team. Worked on these 3 projects:
- RRP (relational robot policy): morphology-general control where a planner samples a structured latent packet, a body-side controller realizes it from proprioception and touch, and every attention layer adds declared relational terms from one registry of 75 factors. More at https://jvboid.dev/projects/rrp
- Ψ0.1: behaviour cloning of the full pretrained Ψ0 humanoid VLA with relational QK attention biases and morphology tokens, against the identical fine-tune without the structure on the SIMPLE benchmark.
- Dissecting Egocentric Action Pretraining in Vision-Language-Action Models (NeurIPS 2026 UniReps workshop): mechanistic study of Ψ0's backbone before and after action pretraining, followed into its action expert. More at https://github.com/JacobFV/vla-action-pretraining
- Jul 2026 – Oct 2026Engineer · SuperCognition Labs
Data engineering, machine learning, research. Worked on these 3 models:
- Whole brain dynamics (SC-WBD-003/004): 26M model that integrates neural dynamics, anatomical priors, and heterogeneous EEG, MEG, fMRI, and intervention data for predicting optimal targets for transcranial magnetic stimulation. More at https://sc-wbd.pages.dev
- Implicit brain model (IBM-1): ~100M mathematically generalized model that materializes task-specific smaller models from shared anatomical, topological, and physiological representations. Modeling the brain implicitly rather than thru an explicitly structured modality mapping allowed us to associate modalities that currently have no datasets and to more efficiently utilize the data trained on. More at https://super-cognition-labs.github.io/IBM-1
- Jan 2026 – Apr 2026API / Integration Architect · AGI, Inc.
Interfaces and integration across our API, SDKs, and other partner-facing surfaces. iOS, on-device llms, model quantization, agents, control plane, etc.
Owned api.agi.tech. First-responder to API infra / full-stack backend issues (Team across 3 countries/timezones, constant pushes directly to production)
- Oct 2025 – Jan 2026Software Engineer · AGI, Inc.
full-stack + infrastructure engineering across agentic systems: typescript, python, react/next.js, node.js, apis, distributed systems, cloud infrastructure, aws, gcp, s3, data engineering, containers, drizzle, pg/psql, databases, queues, browser/computer use, agent runtimes, tool use, model inference, llm integrations, multimodal models, evals, automation, control planes, observability, debugging, deployment, ci/cd, production operations. shipped rapidly across the stack in a high-velocity, production-first environment.
- Apr 2025 – Oct 2025Software Engineer · Breezy
Full-stack product engineering across a rails/next.js monorepo for a prosumer (single-person business) AI receptionist platform.
Independently owned features end-to-end from product requirements and implementation through integration, debugging, and production delivery.
Worked across frontend, backend, ai integrations, and application infrastructure; Left for infra role at AGI Inc
- Sep 2024 – Dec 2024Applied Machine Learning Engineer · Deepshard
Hardware and software for Truffle-1, a personal AI computer running models on-device: enclosure iteration across SLA, FDM and SLS printing against thermal constraints, alongside on-device ML work.
- Jan 2023 – Sep 2024Humanoid Robot Prototyping
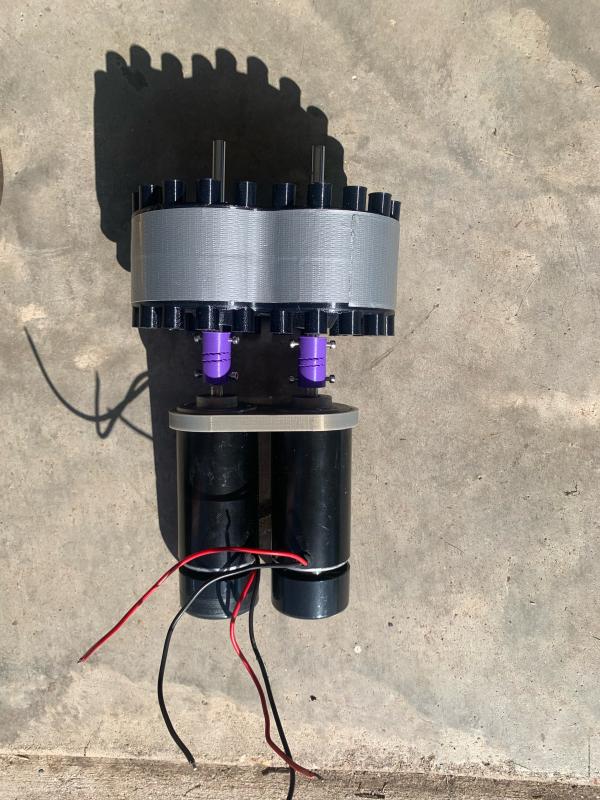
Prototyped hydraulically actuated, endoskeletal humanoid robot: KiCAD, FreeCAD, Blender, Python, 3D printing, mdf board CNC routing, 3/16" A16 plasma cutting, 100um + 300um trace PCB fabrication and SMT assembly (LCSC), 3018 mdf milling. Supplier outreach; worked with Dakings Rapid. Pre-llm engineering.
- Aug 2022 – Jan 2023Software Engineer · Motio, Inc.
Developed Soterre for Qlik Sense
- Jun 2022 – Aug 2022Software Engineer (Intern) · Motio, Inc.
Developed Soterre for Qlik Sense
- Jun 2021 – May 2022Software Developer · IT Lab · UT Arlington
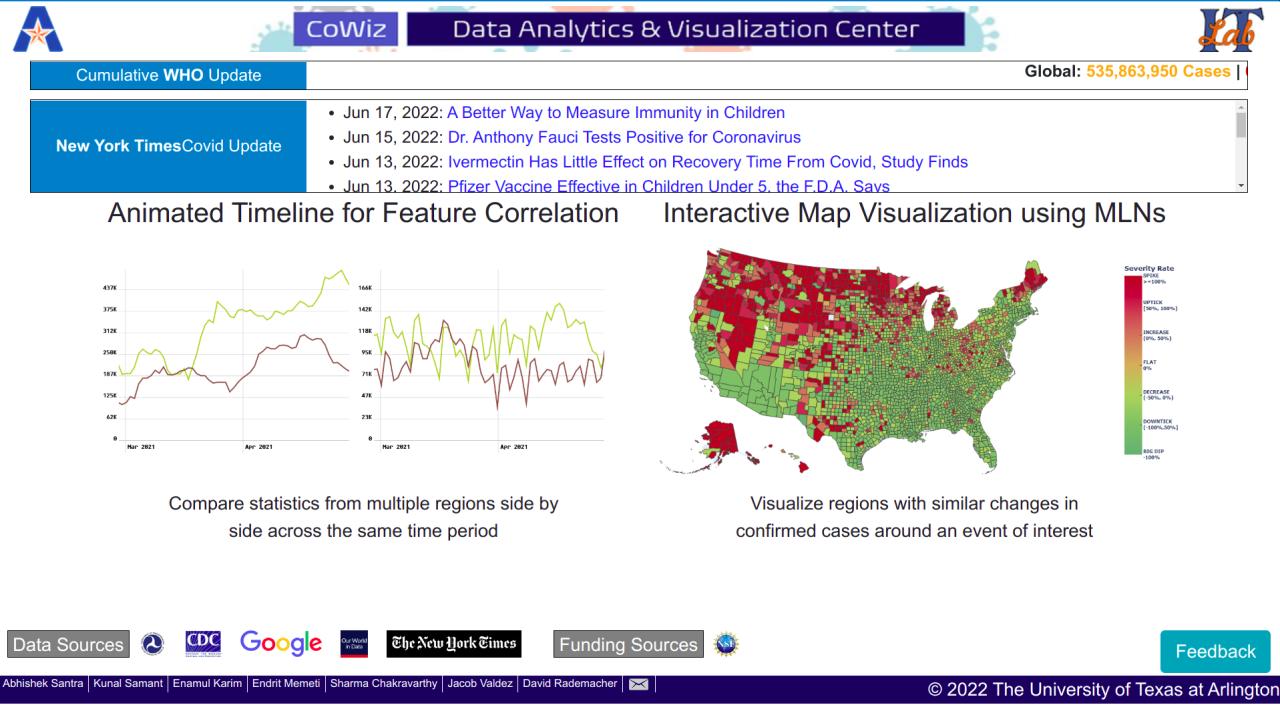
Flask-based statistical visualization tool CoWiz; research group collaboration
Full stack Next-React-GraphQL stack: MLN Dashboard
- Jun 2021 – May 2022Software Developer · College of Social Work · UT Arlington
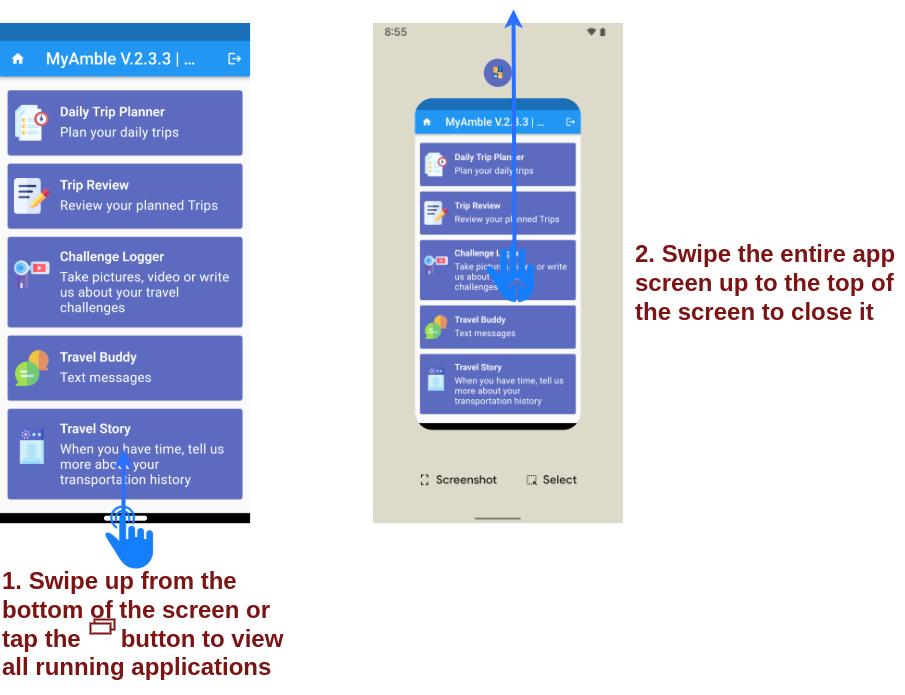
Maintain and enhance multi-platform (iOS and Android) data collecting application MyAmble using flutter and firebase and web administrator interface
- Apr 2020 – Jun 2021
Pandemic + first year at the University of Texas at Arlington
- May 2016 – Mar 2020
- 2020 – 2022B.S., Computer Science · The University of Texas at Arlington
CS coursework alongside heavy lab work, independent ML/robotics prototypes, and a steady research output. GPA 3.6/4.0.
- 2016 – 2018A.A.S., Mathematics · Navarro College
Math associate degree taken dual-credit during high school. GPA 3.9/4.0.
Projects (19)
- Apr 2022 – Dec 2022, Sep 2026
TensorCode: Problem Turning Python objects into tensors and back takes hand-written glue that breaks whenever a type changes. Task Open-source neurosymbolic framework for Python and TypeScript that traces any value through ordinary code and trains only the learned steps. Outcome 89.4% on banking77 after 3.3s of CPU training; published on PyPI and npm. TensaCo/tensacode tensorcode.dev pypi/tensorcode npm/tensorcode · python, typescript, pytorch, differentiable programming
- Sep 2026
Tensegra: Problem Agents reuse stale work, ignore valid tool results and waste compute, and one score can't say which failure happened. Task PyTorch modules for graph-conditioned attention and protected symbolic execution, with causal diagnostics at each model-tool boundary. Outcome 570-run attention study; with full inputs, imitation-bootstrapped dependency-aware policies reached 0.93–0.98 sealed IID success with near-zero invalid reuse, and removing the applicability input raised invalid reuse to 0.41–0.46. JacobFV/tensegra huggingface.co · python, pytorch, typed graphs, recurrent computation
- Sep 2026
Computerworld: Problem Computer-use agents train on real VMs that can't be replayed or cheaply forked, so RL is slow and bugs don't reproduce. Task One deterministic Rust engine simulating machines, shells, apps, a browser and an internet, shipped native, on PyPI and on npm. Outcome 265 µs fork, 4.78 µs step across 5 machines, 93 services and 87 sites, with cross-platform pixel parity. ComputaCo/computerworld computaco.ai pypi/computerworld npm/computerworld · rust, wasm, pyo3, wasm-bindgen, cpu rasterizer, simulation
- Sep 2026
IBM-1: Problem EEG, MEG and vision data are rarely trained together, so each brain model sees only one slice. Task One shared 3.84M kernel lazily materialized into 16 models across EEG, MEG, vision and a musculoskeletal body. Outcome 63.5% image-to-EEG retrieval (127× chance); the body stays upright with 0.17 mm drift under a 5 N push. Super-Cognition-Labs/IBM-1 Talk super-cognition-labs.github.io/IBM-1 · python, mne, opensim
- Aug 2026
langcurriculum: Problem Fixed reasoning benchmarks leak into training data, so scores can't separate reasoning from memorization. Task Zero-dependency procedural curriculum: 180 self-grading lesson generators, rendered in 411 languages and five media. Outcome Unlimited contamination-free episodes without using any data, gated by 4,026 tests. JacobFV/formal-language-cirriculum jacobfv.github.io · python, sqlite, unification grammar, dsp
- Aug 2026
jterm: Problem When a machine crashes, terminals lose the command you typed but never ran. Task Mirrored every readline edit to crash-safe snapshots, with tmux-style splits that never restart the shell. Outcome Survives SIGKILL with scrollback and unsent commands intact; 155 tests, installers for macOS, Windows and Linux. JacobFV/jterm jacobfv.github.io/jterm · rust, tauri, typescript, react, xterm.js, codemirror, three.js
- Aug 2026
SC-WBD: Problem EEG, fMRI, stimulation and behaviour each see a different slice of the brain, so their results rarely combine. Task 414-region whole-brain dynamics model fusing all four through physics forward operators, released behind a claim gate. Outcome Four public checkpoints; the 26.3M-param SC-WBD-003 beat every baseline on 27 held-out participants. JacobFV/sc-wbd sc-wbd.pages.dev · pytorch, python, mne, nibabel, e-field solvers
- Jun 2026
fieldratchet: Problem PCB layout is done by hand, and none of that intuition compounds back into the tool. Task Self-improving layout compiler whose oscillator placement engine mutates itself, gated by an independent EMI solver. Outcome Beat simulated annealing by 78% on a 187-component board; an evolved optimizer improved an unseen board ~24%. Finalist in AI Engineer World's Fair Hackathon 2026. JacobFV/fieldratchet · typescript, remotion, electron, kicad, mojo/max, kuramoto oscillators, emi simulation
- Jan 2026 – May 2026
canvas-engineering: Problem World models hide their causal structure in weights, so nobody can check what is allowed to influence what. Task Compiler that lowers a typed schema of latent regions, connectivity and clocks into attention masks on a stock diffusion transformer. Outcome Across 236 runs, matched dense accuracy with 19.6% of the connections and ~5× faster training. commandAGI/canvas-engineering Post · python, pytorch, diffusion transformers, cogvideox, pydantic, world models, neurosymbolic, research
- May 2026
SynthUX: Problem Computer-use agents need grounded training data, but recording full VMs is expensive. Task Generator that expands goals into grammar trees and replays them as real input in three browser desktop simulators. Outcome Published a Hugging Face dataset of 1,949 frames: 81.1% app-native, 0 validator errors. JacobFV/synthux · python, node tree grammars, svelte simulators, hugging face datasets, computer-use agents, synthetic data
- Nov 2025 – May 2026
browser-os · windows-web-next · macos-web-next: Problem Computer-use agents need desktops that are inspectable and instantly resettable, which real OSes aren't. Task Svelte desktop shell (windows, filesystem, app lifecycle) with Windows 11 and macOS simulations and 20+ apps. Outcome Live on Vercel as SynthUX's substrates: 100% app-native on macOS, 81.1% across all three. JacobFV/browser-os JacobFV/windows-web-next JacobFV/macos-web-next desktop-shell.vercel.app windows-web-next.vercel.app macos-web-next.vercel.app · typescript, svelte, vercel, html2canvas, computer-use agents
- May 2026
Chem-0: Problem A real chemistry bench brings calibration, occlusion and contact that no API abstracts away. Task MCP stack letting an agent drive a low-cost SO-101 arm from a live camera, with IK, YOLO vial analysis and an Electron console. Outcome The agent posed a real arm from camera feedback; the failed vial grasp pinned the blockers: calibration, compliance, fast local control. JacobFV/chem-0 Post · lerobot so-101, python, opencv, placo, yolo, mcp, typescript, electron, robotics
- May 2026
Trash Sorter: Problem Trash sorting is a valuable robot job, once calibration, perception and grasping hold up. Task Calibrated, teleoperated and tuned a LeRobot SO-101 arm with camera perception to pick and sort trash. Outcome Prototype built by a team of four in one weekend at Founders Inc Physical AI Hack. · lerobot, so101 arm, computer vision, robotics, teleoperation
- Apr 2026
Lunar Rover: Problem Off-world robots can't be joysticked, so autonomy has to survive relays and ground control. Task Regolith-collecting rover on a four-node stack (viewer, ground control, satellite relay, robot) with LLM route planning. Outcome Working rover and mission demo in one weekend at RoboHacks at Y Combinator. Post · robotics, llm route planning, mars robots, distributed control, autonomy
- Feb 2026
The Tensor Computer: Problem LLM agents spend 20–50 tokens on what one machine instruction does; could programs be learned as machine code instead? Task Rebuilt a full von Neumann computer (ALU, cache, memory, GPU) as differentiable JAX tensor ops. Outcome 4 independent backends agree on 59 conformance vectors; a self-hosting C compiler matches the host's output byte for byte. · python, jax, c, rust, c++, differentiable programming, program synthesis, research
- Jan 2026
precisionBOM: Problem Hardware teams source parts by hand across spreadsheets and vendor pages. Task Next.js app over a Python multi-agent service that matches each BOM line against DigiKey's live catalog. Outcome Shipped precisionbom.com: live stock, price breaks and alternates in one pass, exported as an orderable BOM. First place ($1000) at AI Agents & MCP Hardware Hackathon. precision-bom/precisionBOM precisionbom.com · next.js, python, multi-agent systems, digikey api, hardware procurement
- Mar 2025
bsbr: Problem Attention cost grows quadratically with sequence length, making long context expensive. Task Pip-installable attention: exact within chunks, retrieval over compressed chunk states, plus a GPT-2 converter. Outcome 5.6× faster than linear attention and 30× faster than DeltaNet at 1,024 tokens. JacobFV/bsbr Post pypi/bsbr · python, pytorch, transformers, hugging face, pypi, research
- Sep 2021 – Nov 2021
jnumpy: Problem UT Arlington ML courses banned third-party frameworks, so every assignment meant rewriting backprop. Task Built my own numpy deep-learning library with arbitrary-DAG autodiff and neural-network and RL abstractions. Outcome Carried my homework across three ML courses; later added connect-4 RL and a C port. JacobFV/jnumpy · python, numpy, autograd, deep learning, reinforcement learning
- Jan 2021 – May 2021
DesparadosAEye: Problem Mobile chatbots need cloud servers that cost money and expose user data. Task Led a 5-person team porting Facebook's BlenderBot-small to TFLite for on-device Android inference. Outcome 335M-parameter chatbot running fully on-device; presented at UTA Innovation Day 2021. kmosoti/DesparadosAEYE · kotlin, java, sqlite, android, tensorflow lite, blenderbot, hugging face
Skills (ATS)
Languages: Python, TypeScript, SQL, Rust, C, Java, Kotlin
AI / ML: deep learning, transformers, diffusion models, world models, reinforcement learning, foundation models, computer vision, LLMs, PyTorch, JAX, Hugging Face
Agents: AI agents, multi-agent systems, computer use, tool use, Model Context Protocol (MCP), evals
Robotics / Hardware: robot learning, imitation learning, manipulation, LeRobot, MuJoCo, embedded firmware, ESP32, PCB design, KiCAD, CAD, 3D printing
Infrastructure / Web: distributed systems, data pipelines, PostgreSQL, AWS, GCP, Cloudflare Workers, Vercel, CI/CD, React, Next.js, Node.js, FastAPI
Mobile: iOS, Android, React Native, Flutter