Chem-0 X thread
A six-post X thread on Chem-0, the SO-101 robot arm setup, the two-layer action interface, and why calibration and feedback became the real bottlenecks.
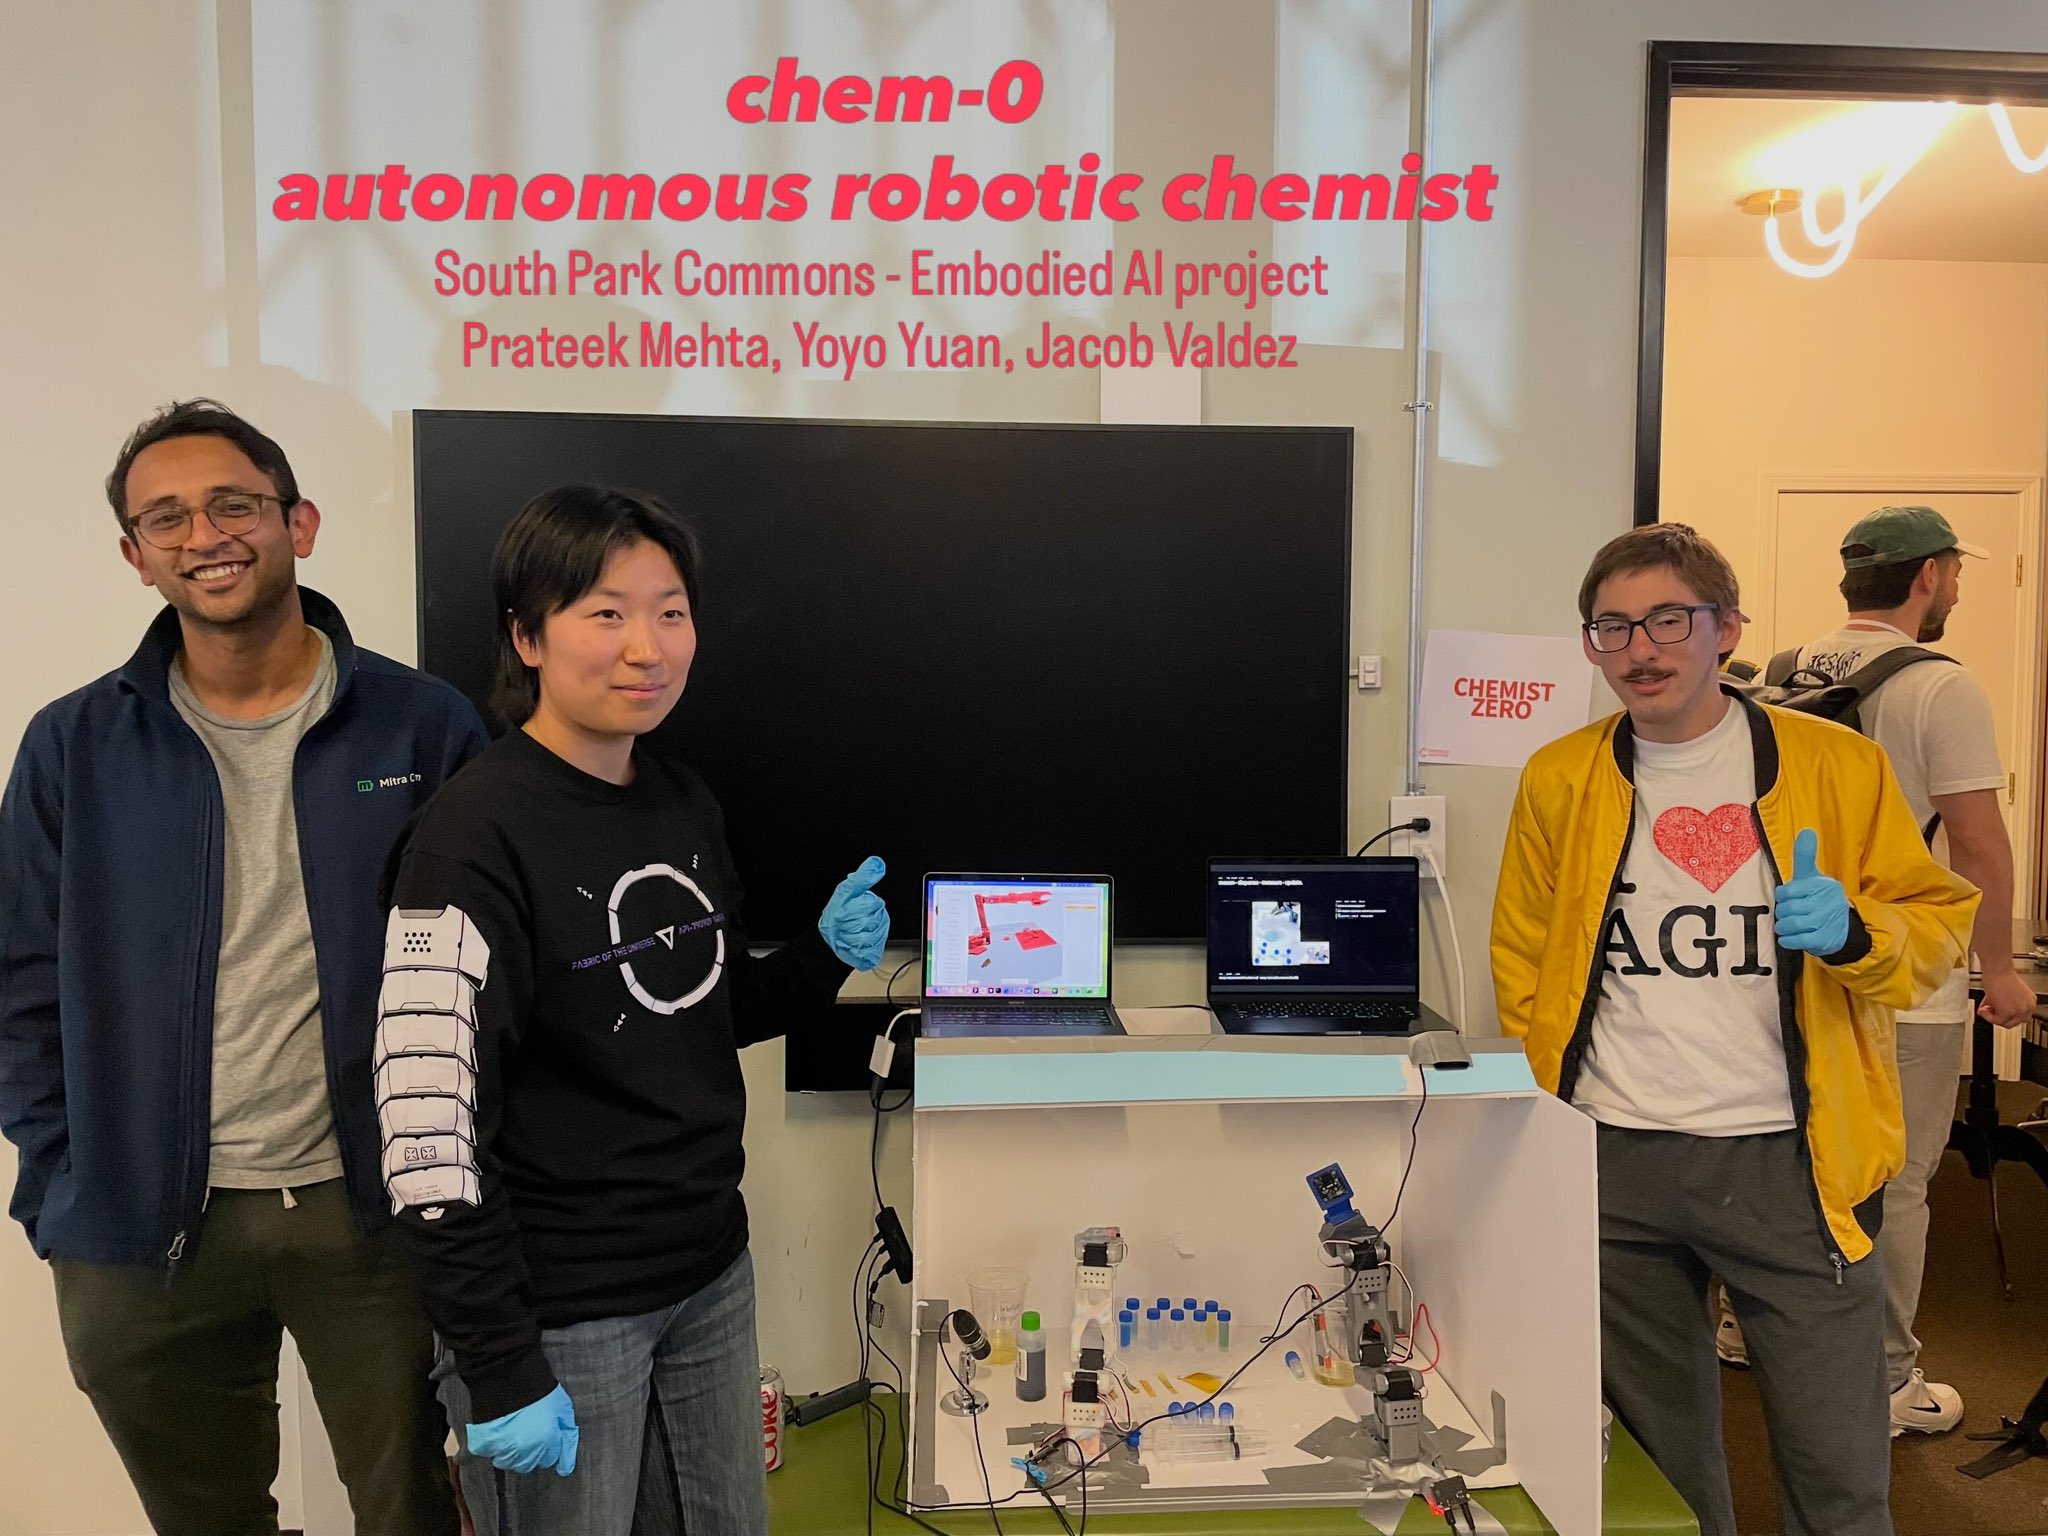
reflections working on chem-0 (autonomous robotic chemistry lab) with Prateek Mehta and Yoyo Yuan (@adiabaticgarden) (0/5 🧵)
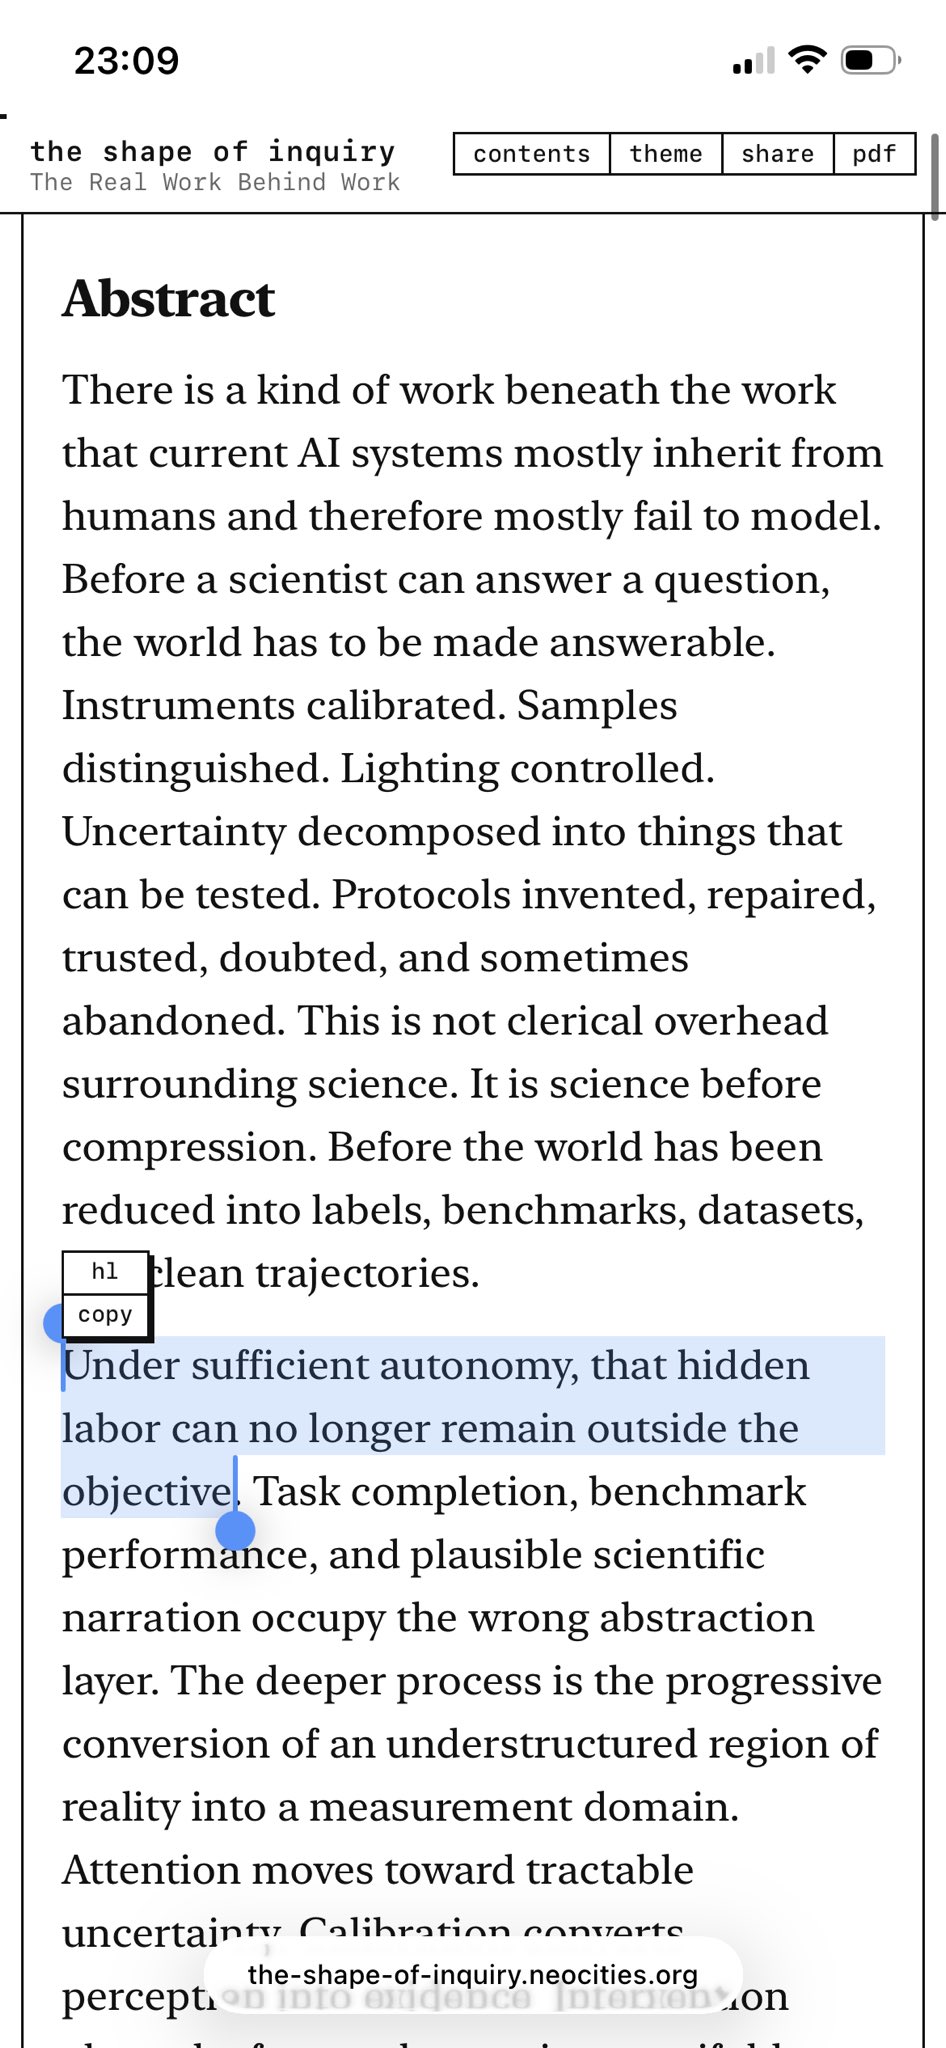
(1/5) we met last week preparing for the @southpkcommons embodied ai hackathon with a very over-scoped but directionally starting focus (the-shape-of-inquiry.neocities.org): could we build a general robotic chemistry system that was ACTUALLY interfacing with reality itself instead of just…
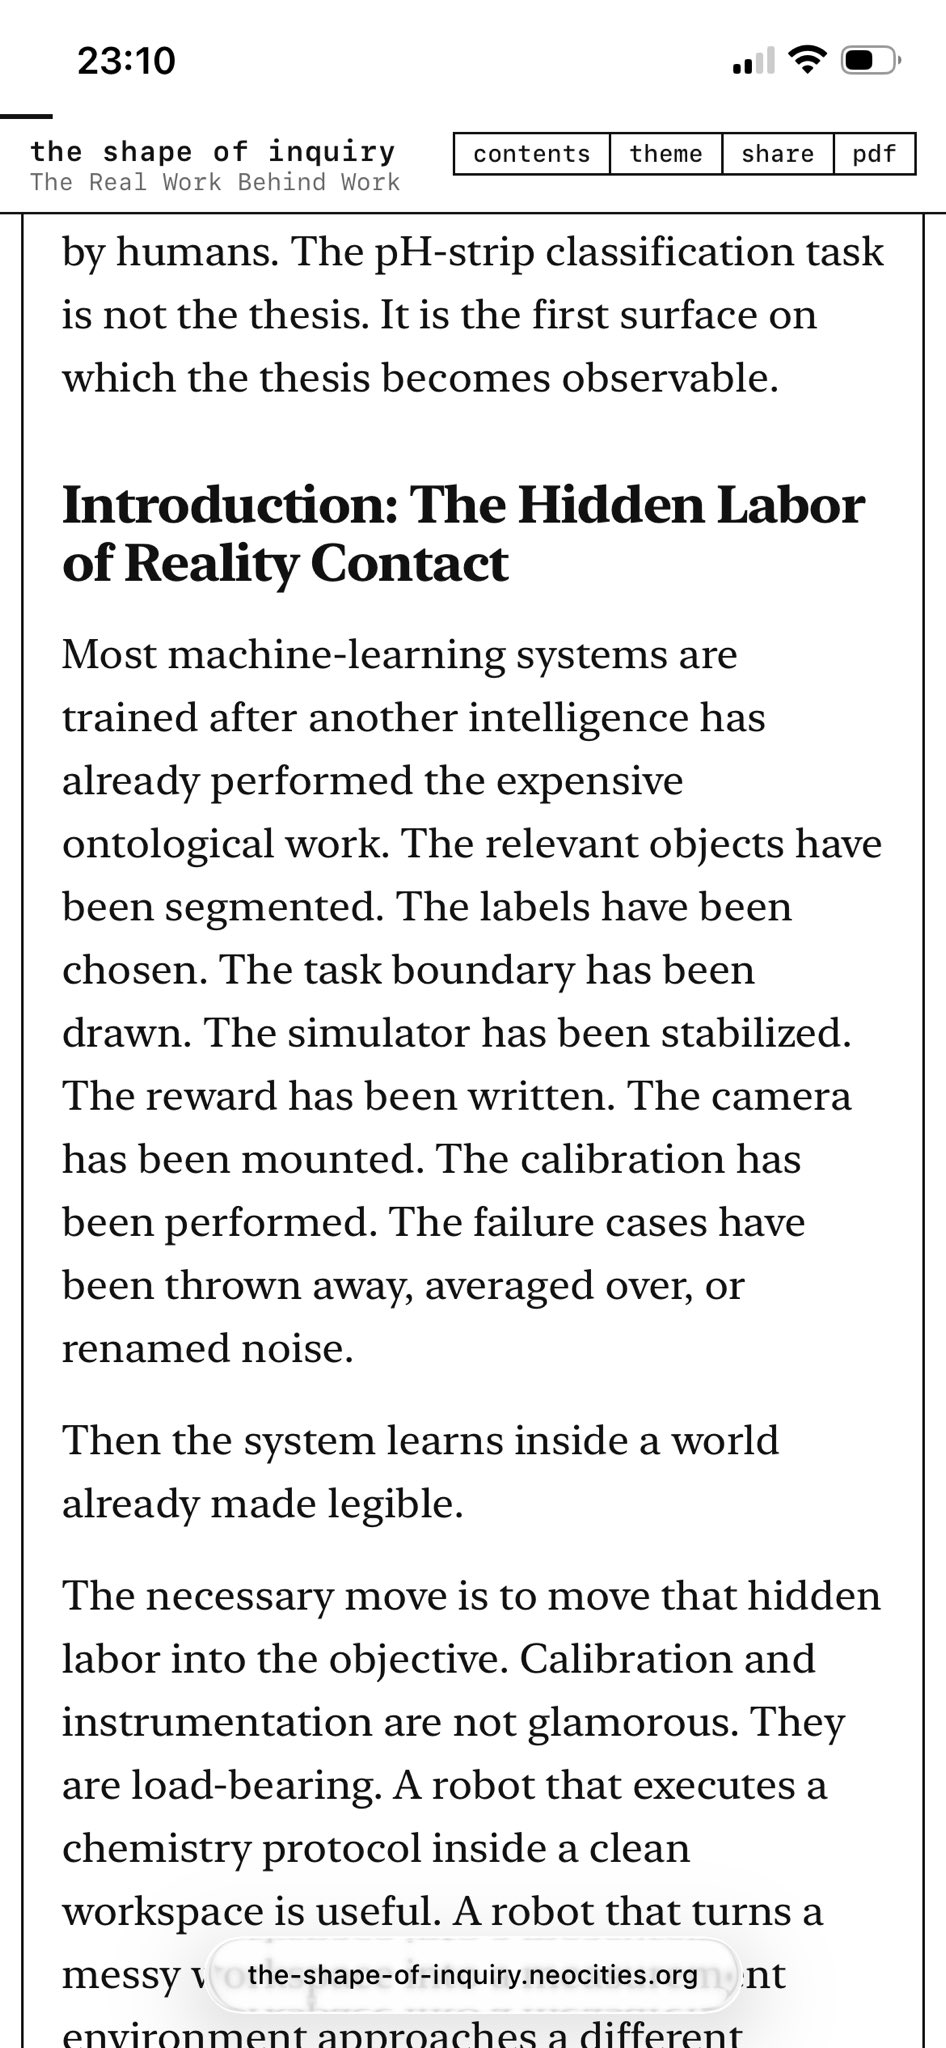
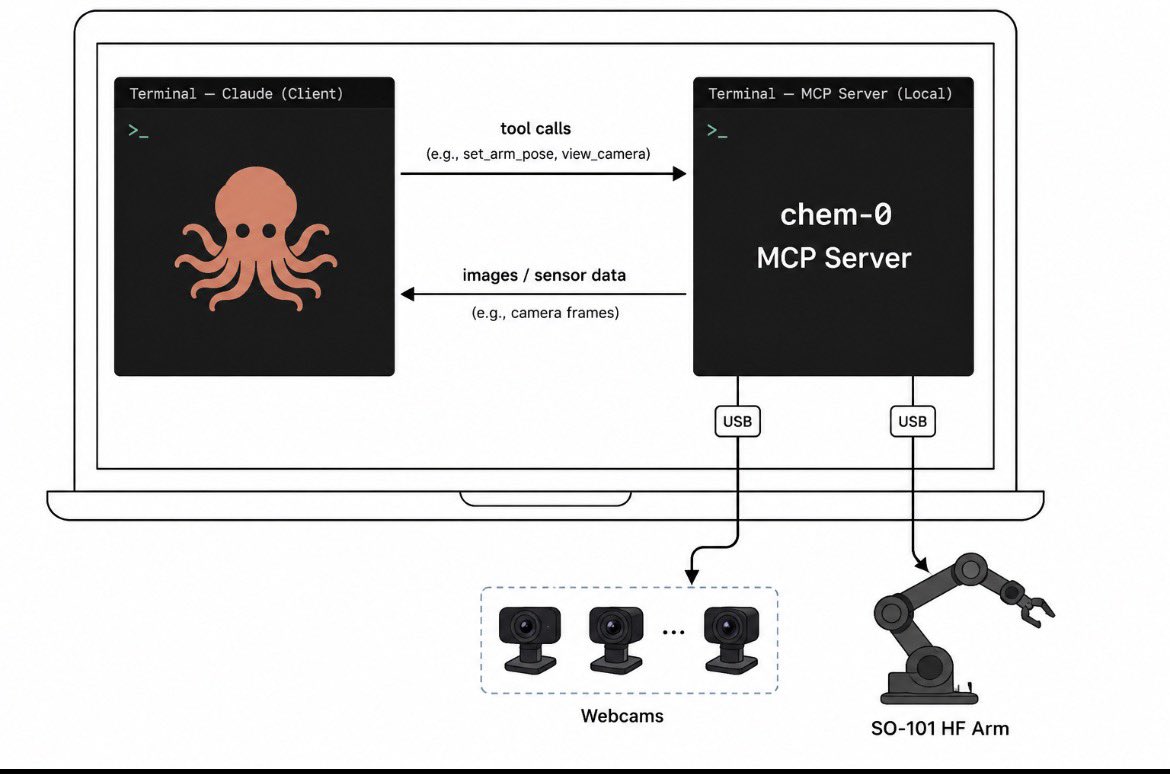
(2/5): we started with some scope cuts to just get an mvp demo-able: only chem-1101 aqueous solution lab equipment, (initially) no custom agent, and we used a pre-assembled SO-101 hf arm instead of making our own hardware
we initially made a python mcp server to give claude code…
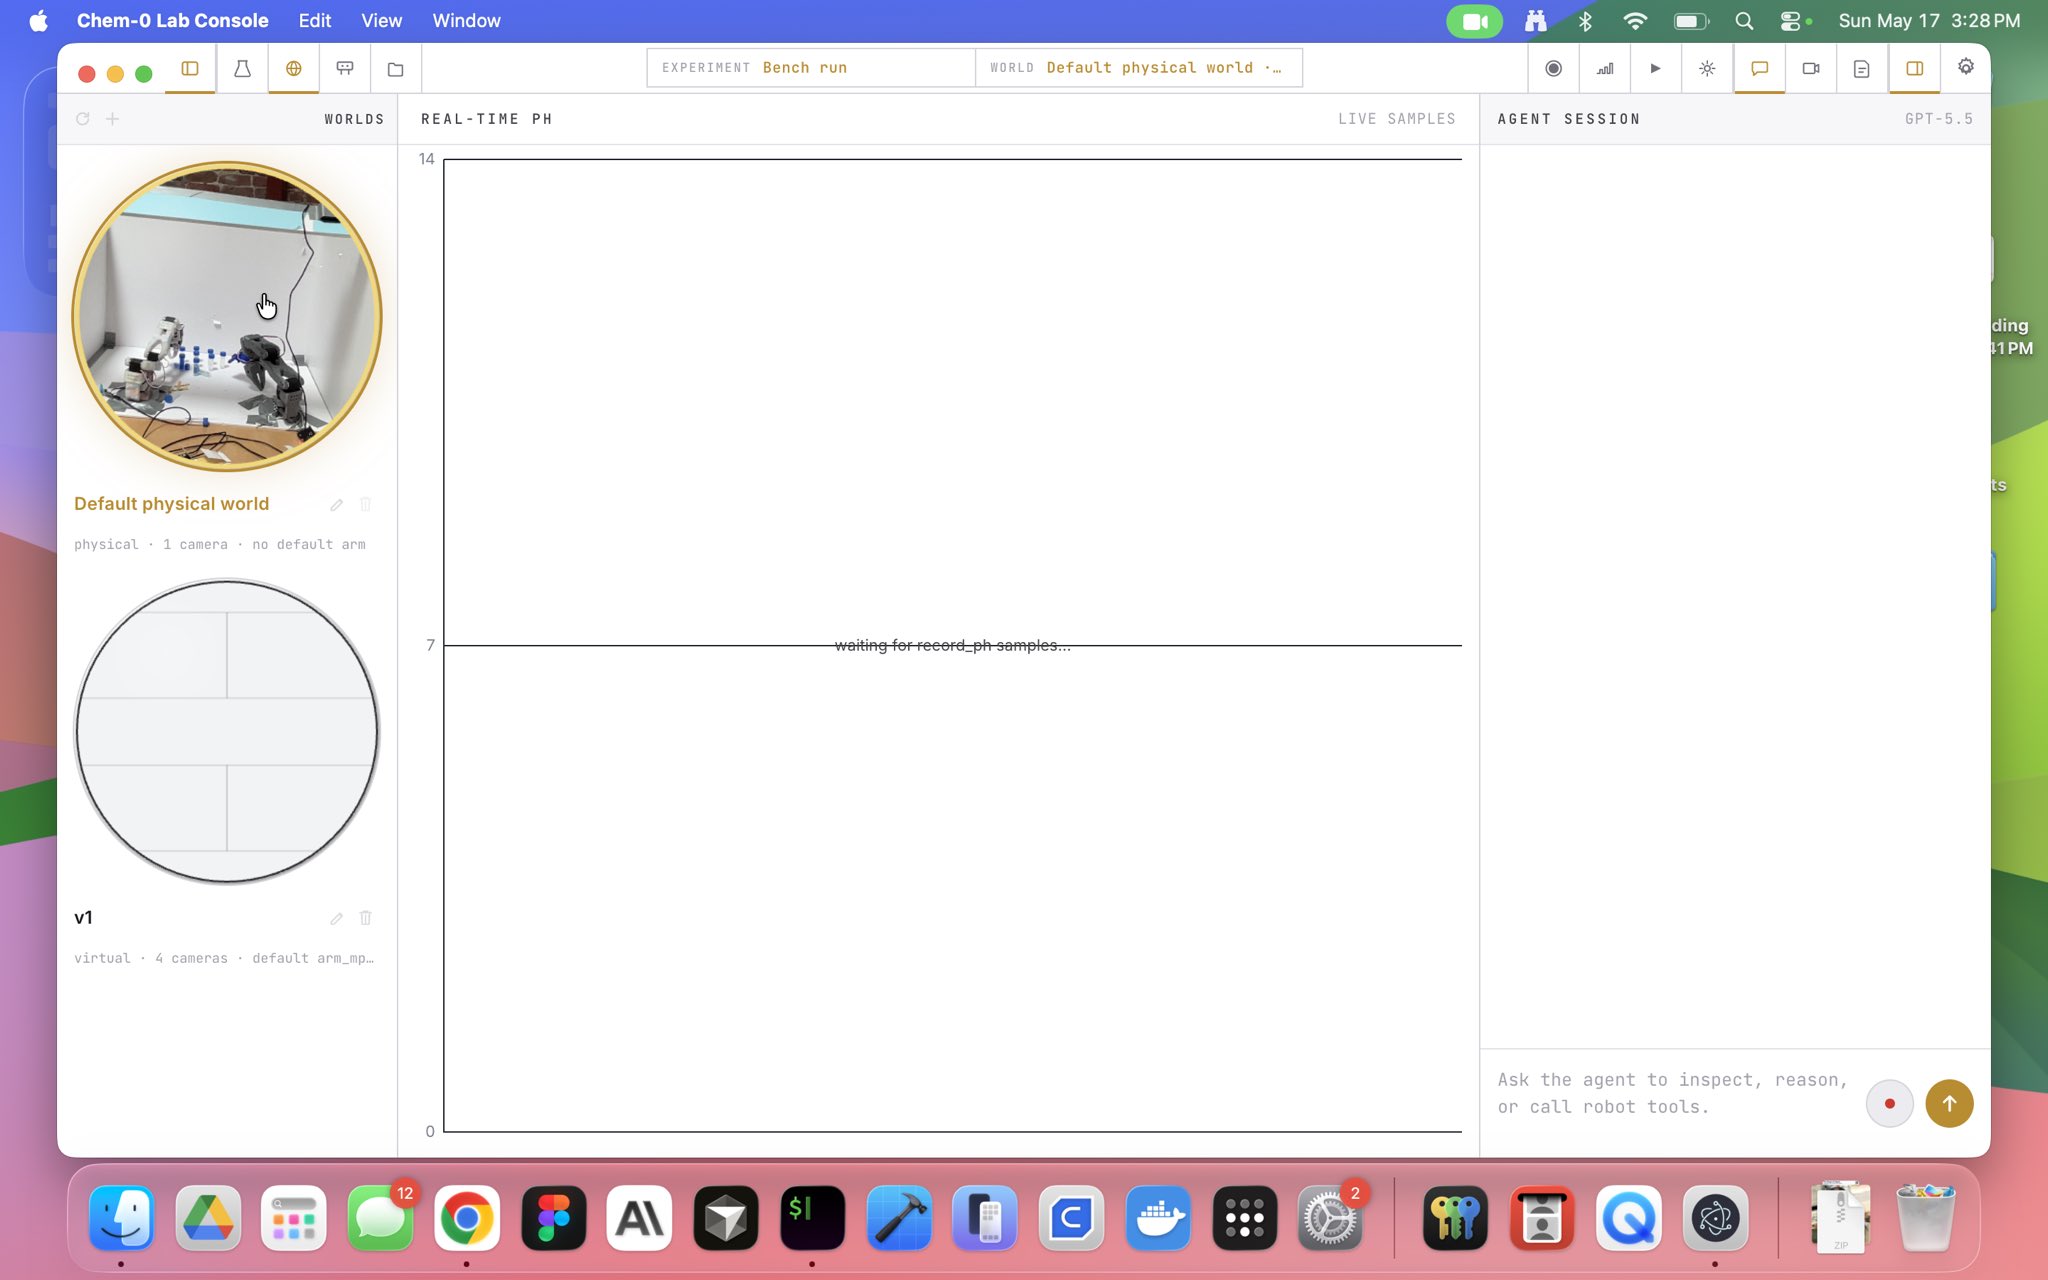
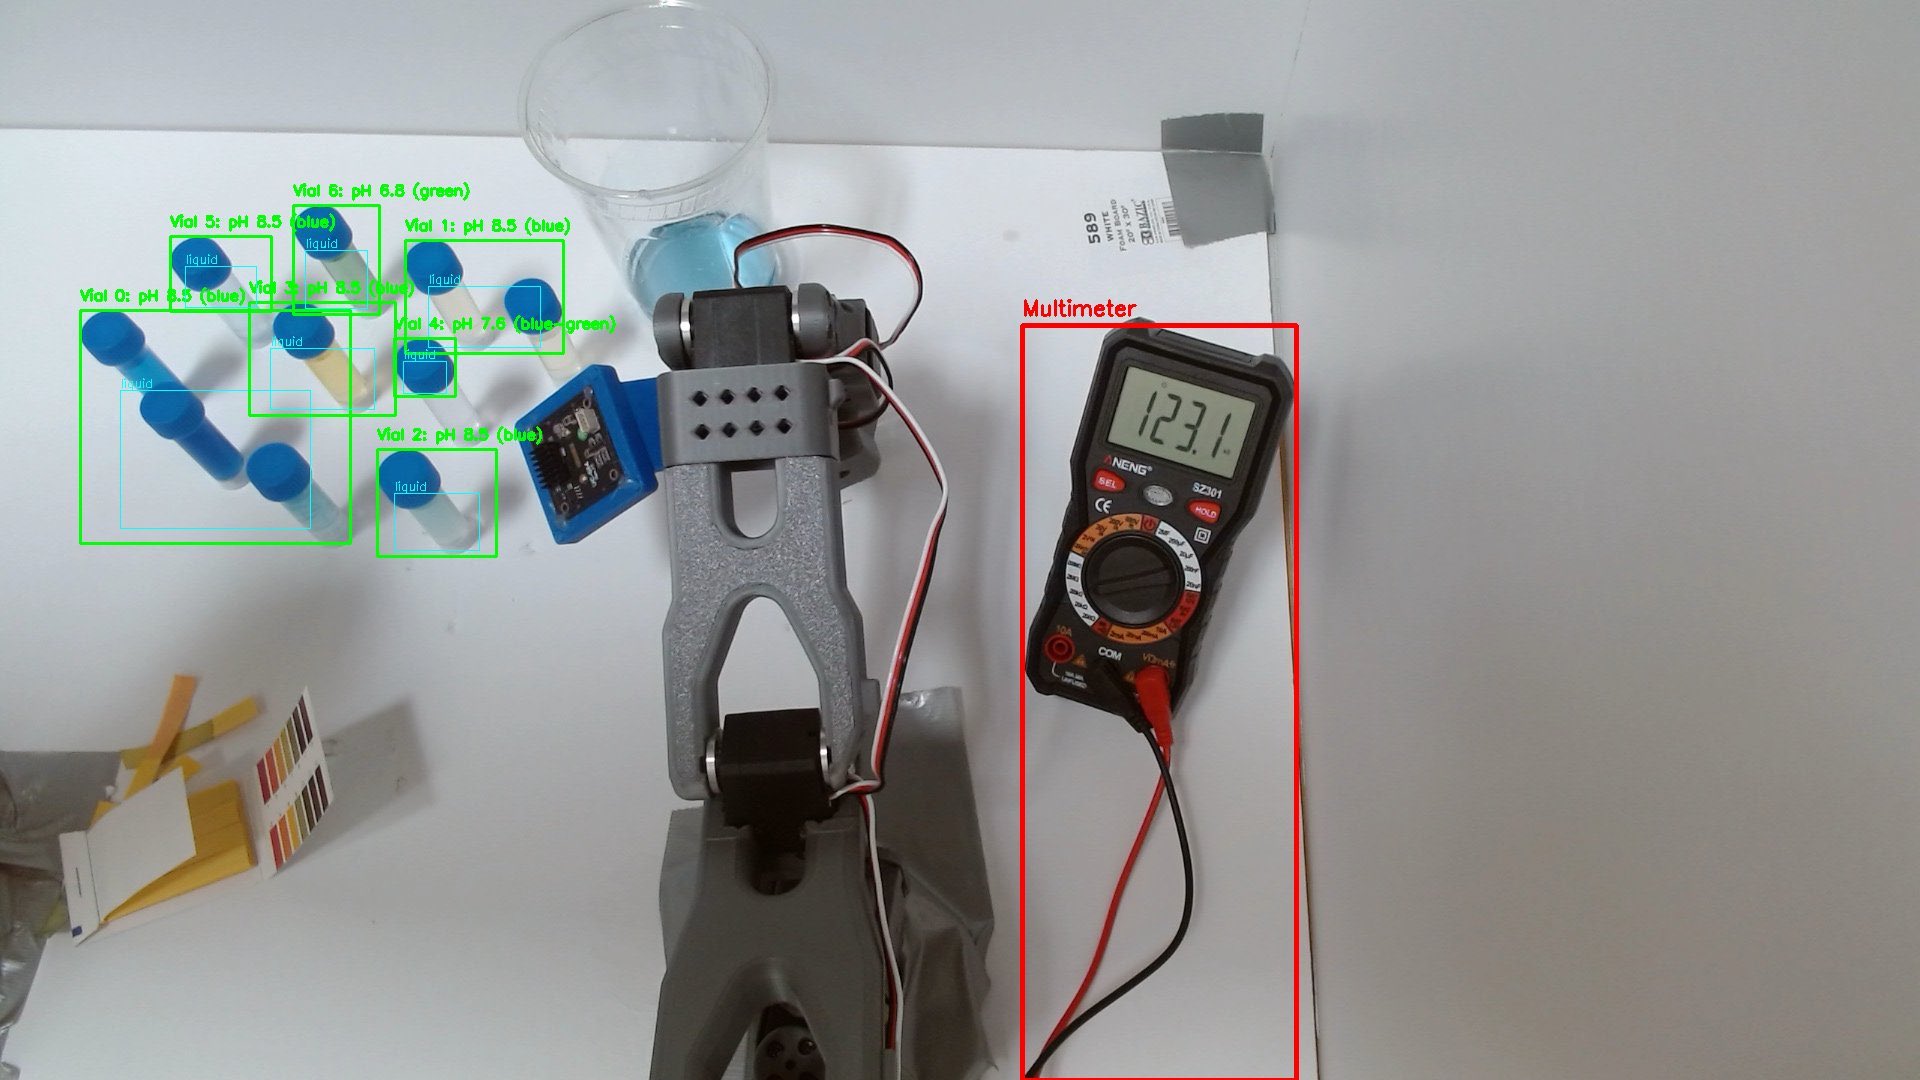
(3/5): there was early optimism setting the vlm move its arm around in free-range. it had a small pose table to extrapolate from and three hours into friday evening we could already see it move its arm to general “extended”/“retracted”/“all the way to the left” poses on command…
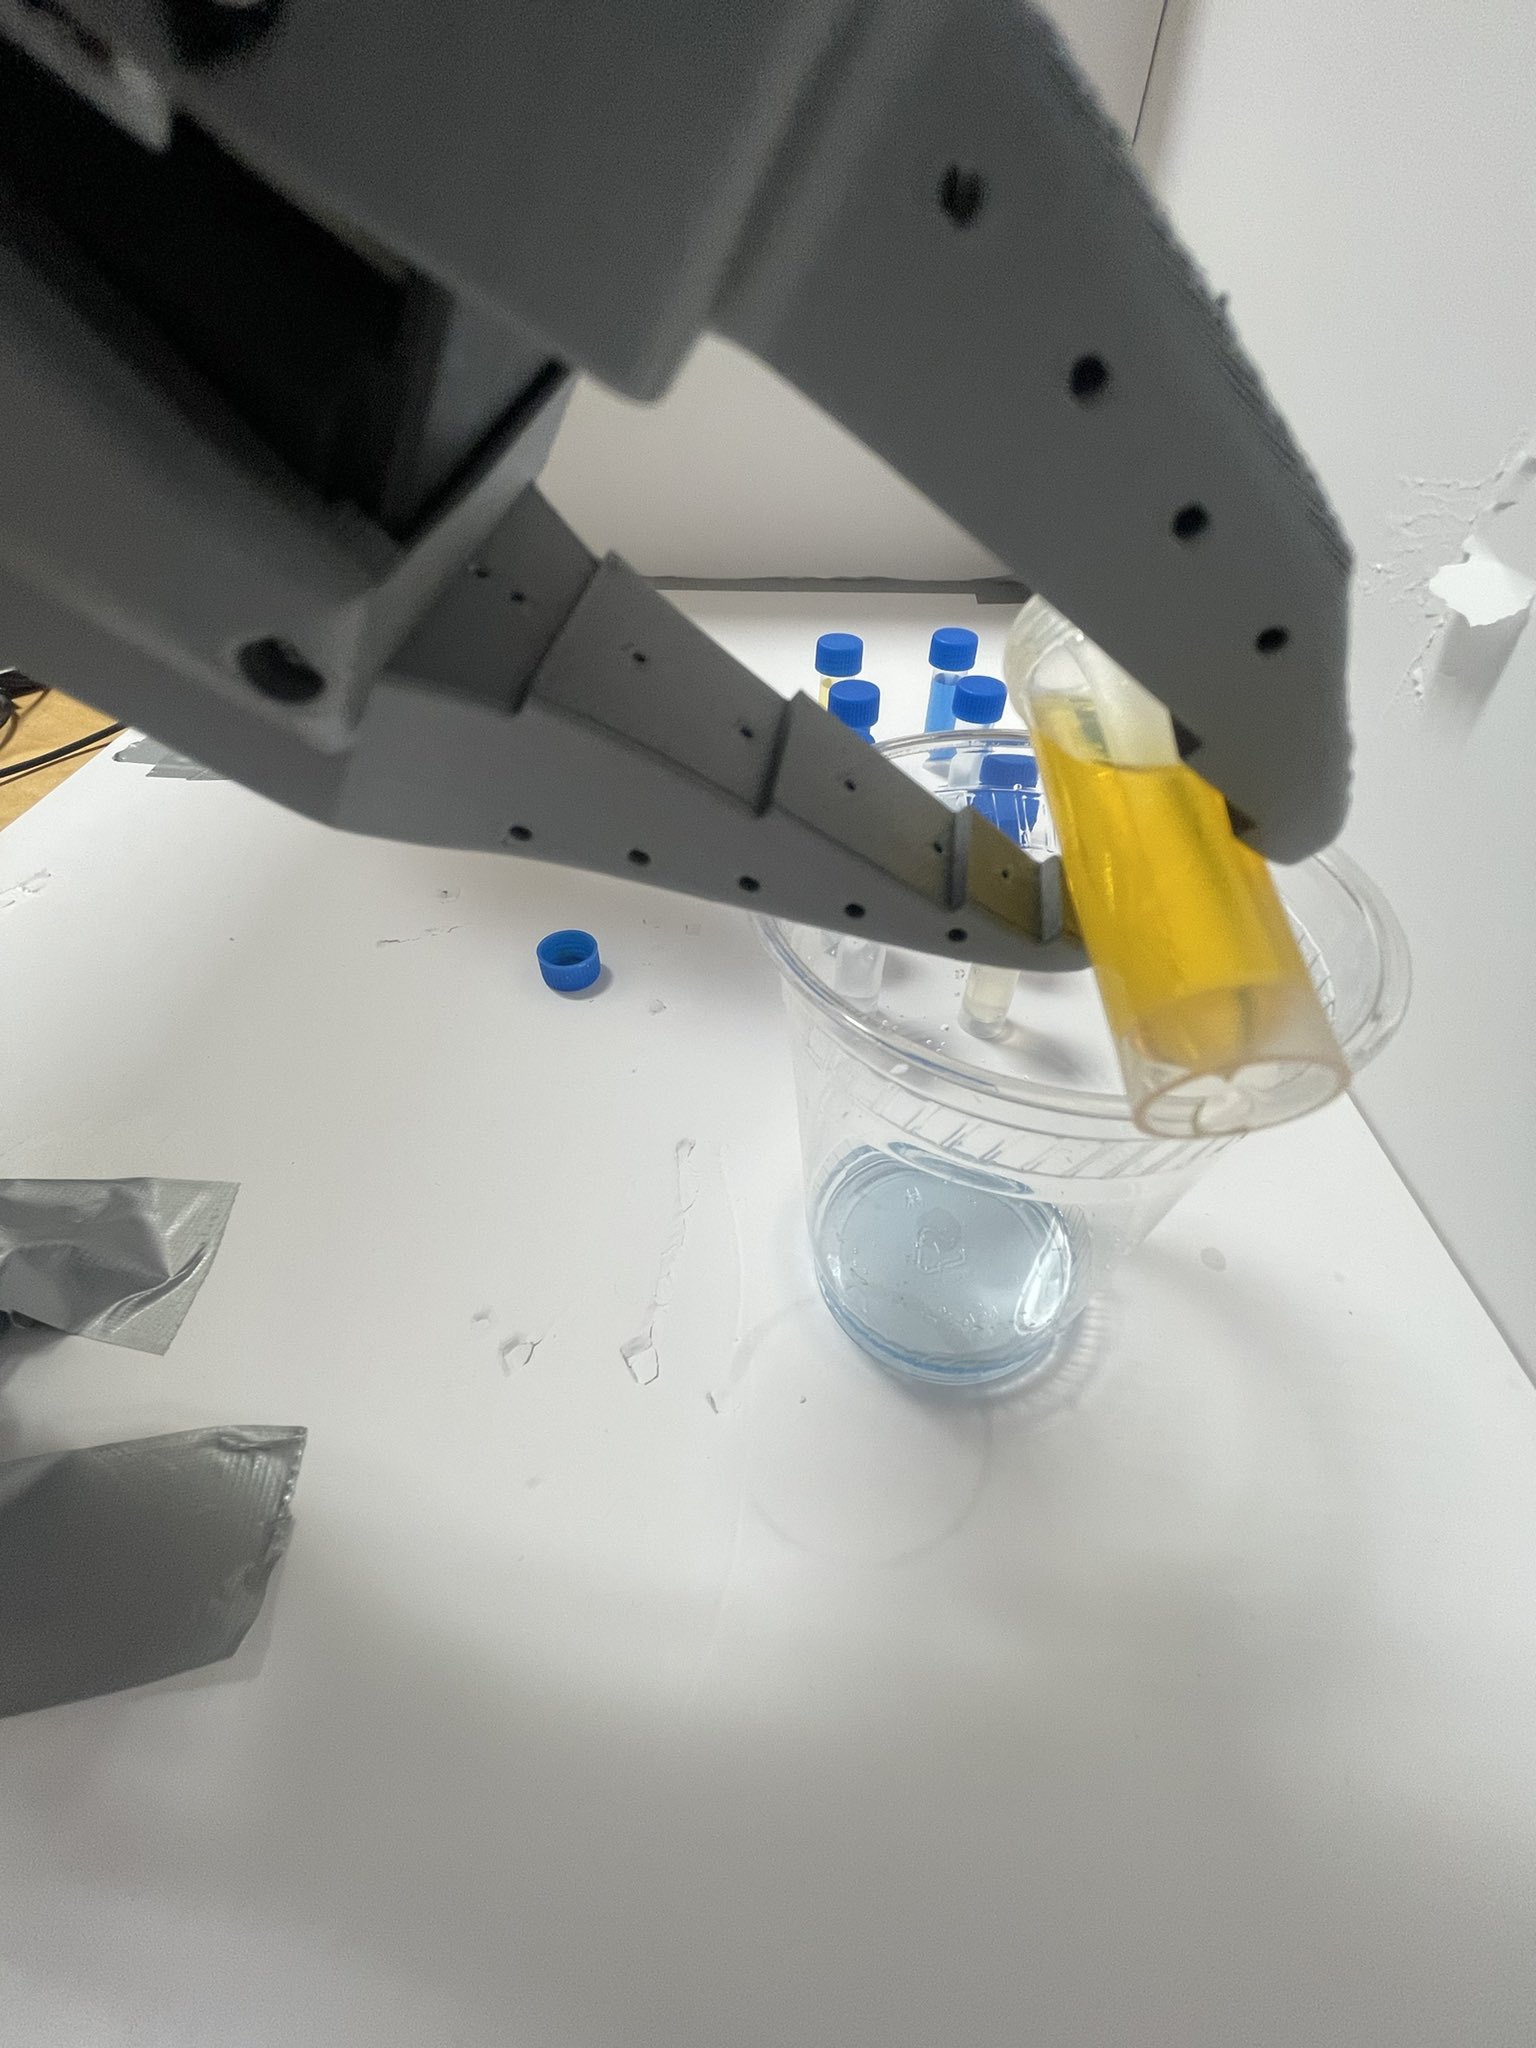
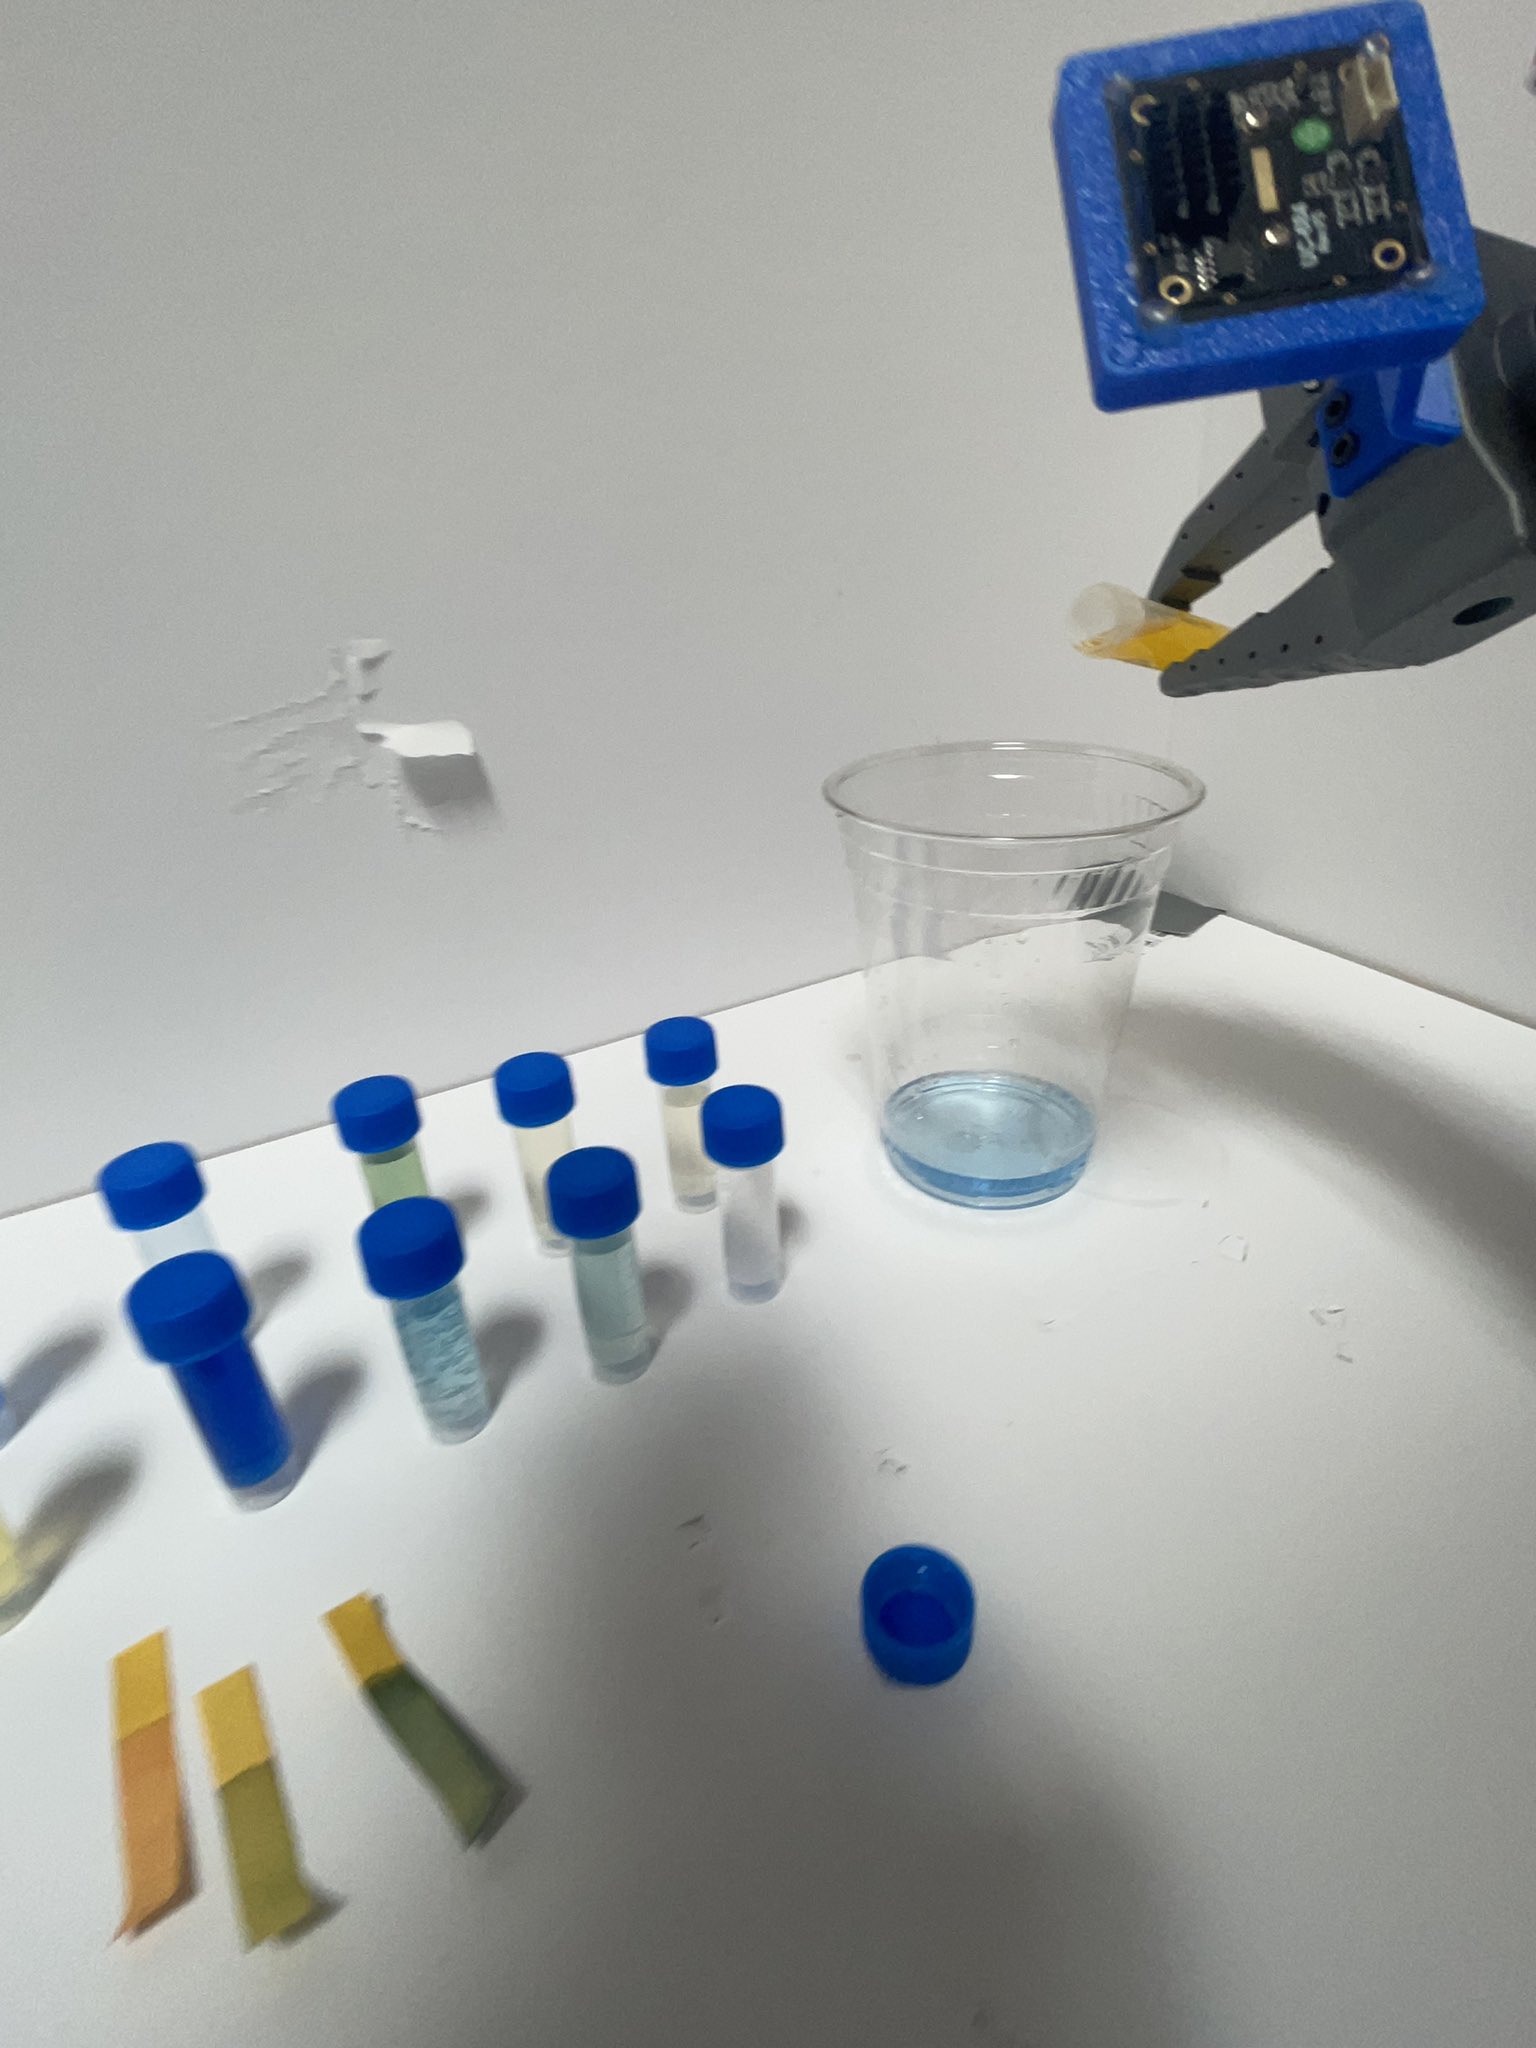
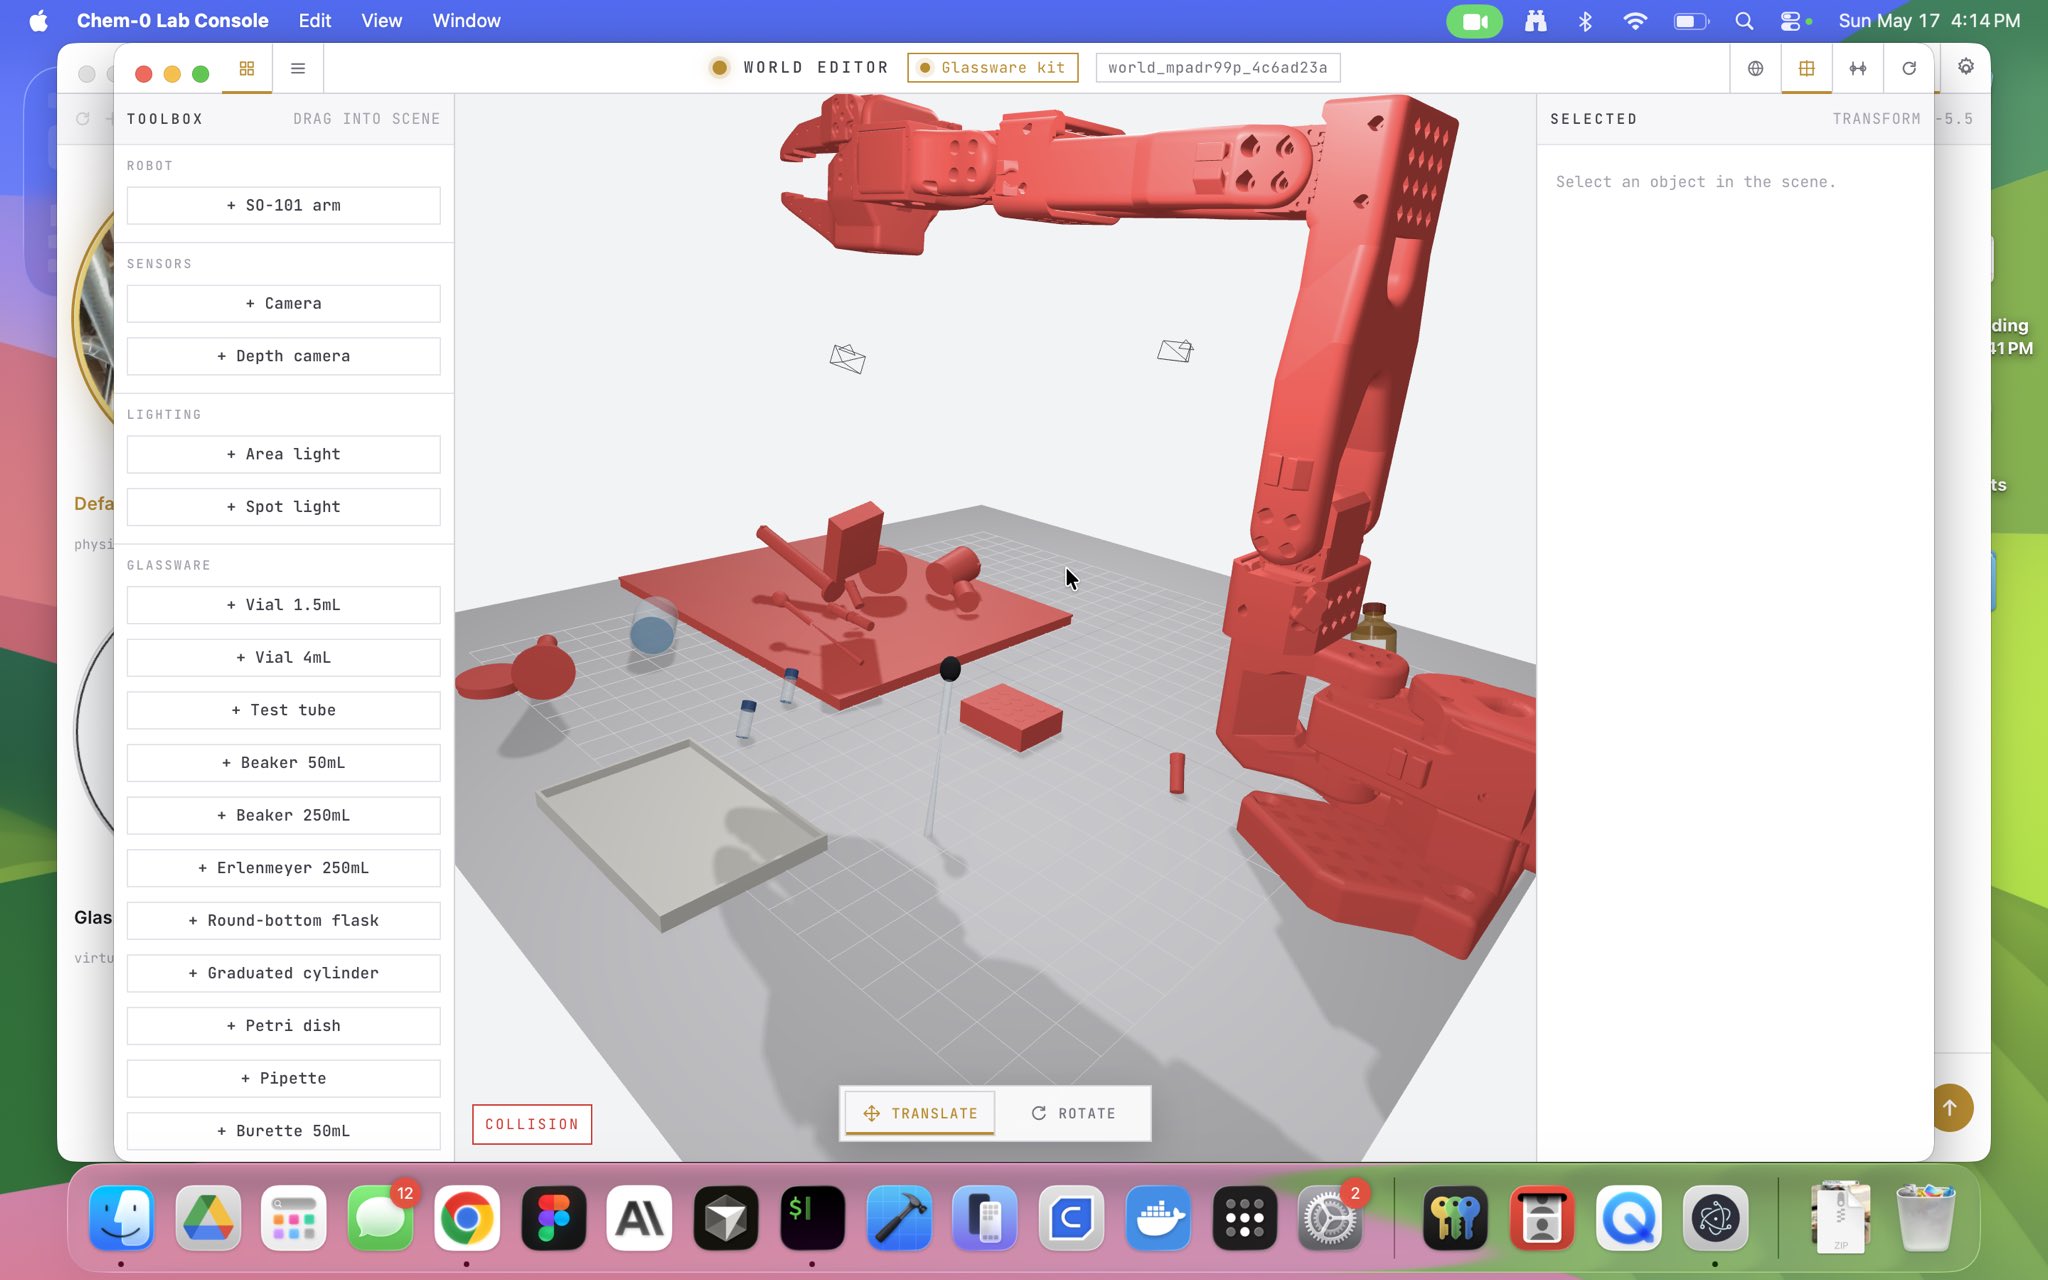
(4/5): so i know the thesis was all about robots actually touching reality but these failures partially pushed us BACK into simulator territory
once grasping became the bottleneck, we stopped focusing on the higher level goals we wanted to achieve and just worked on…
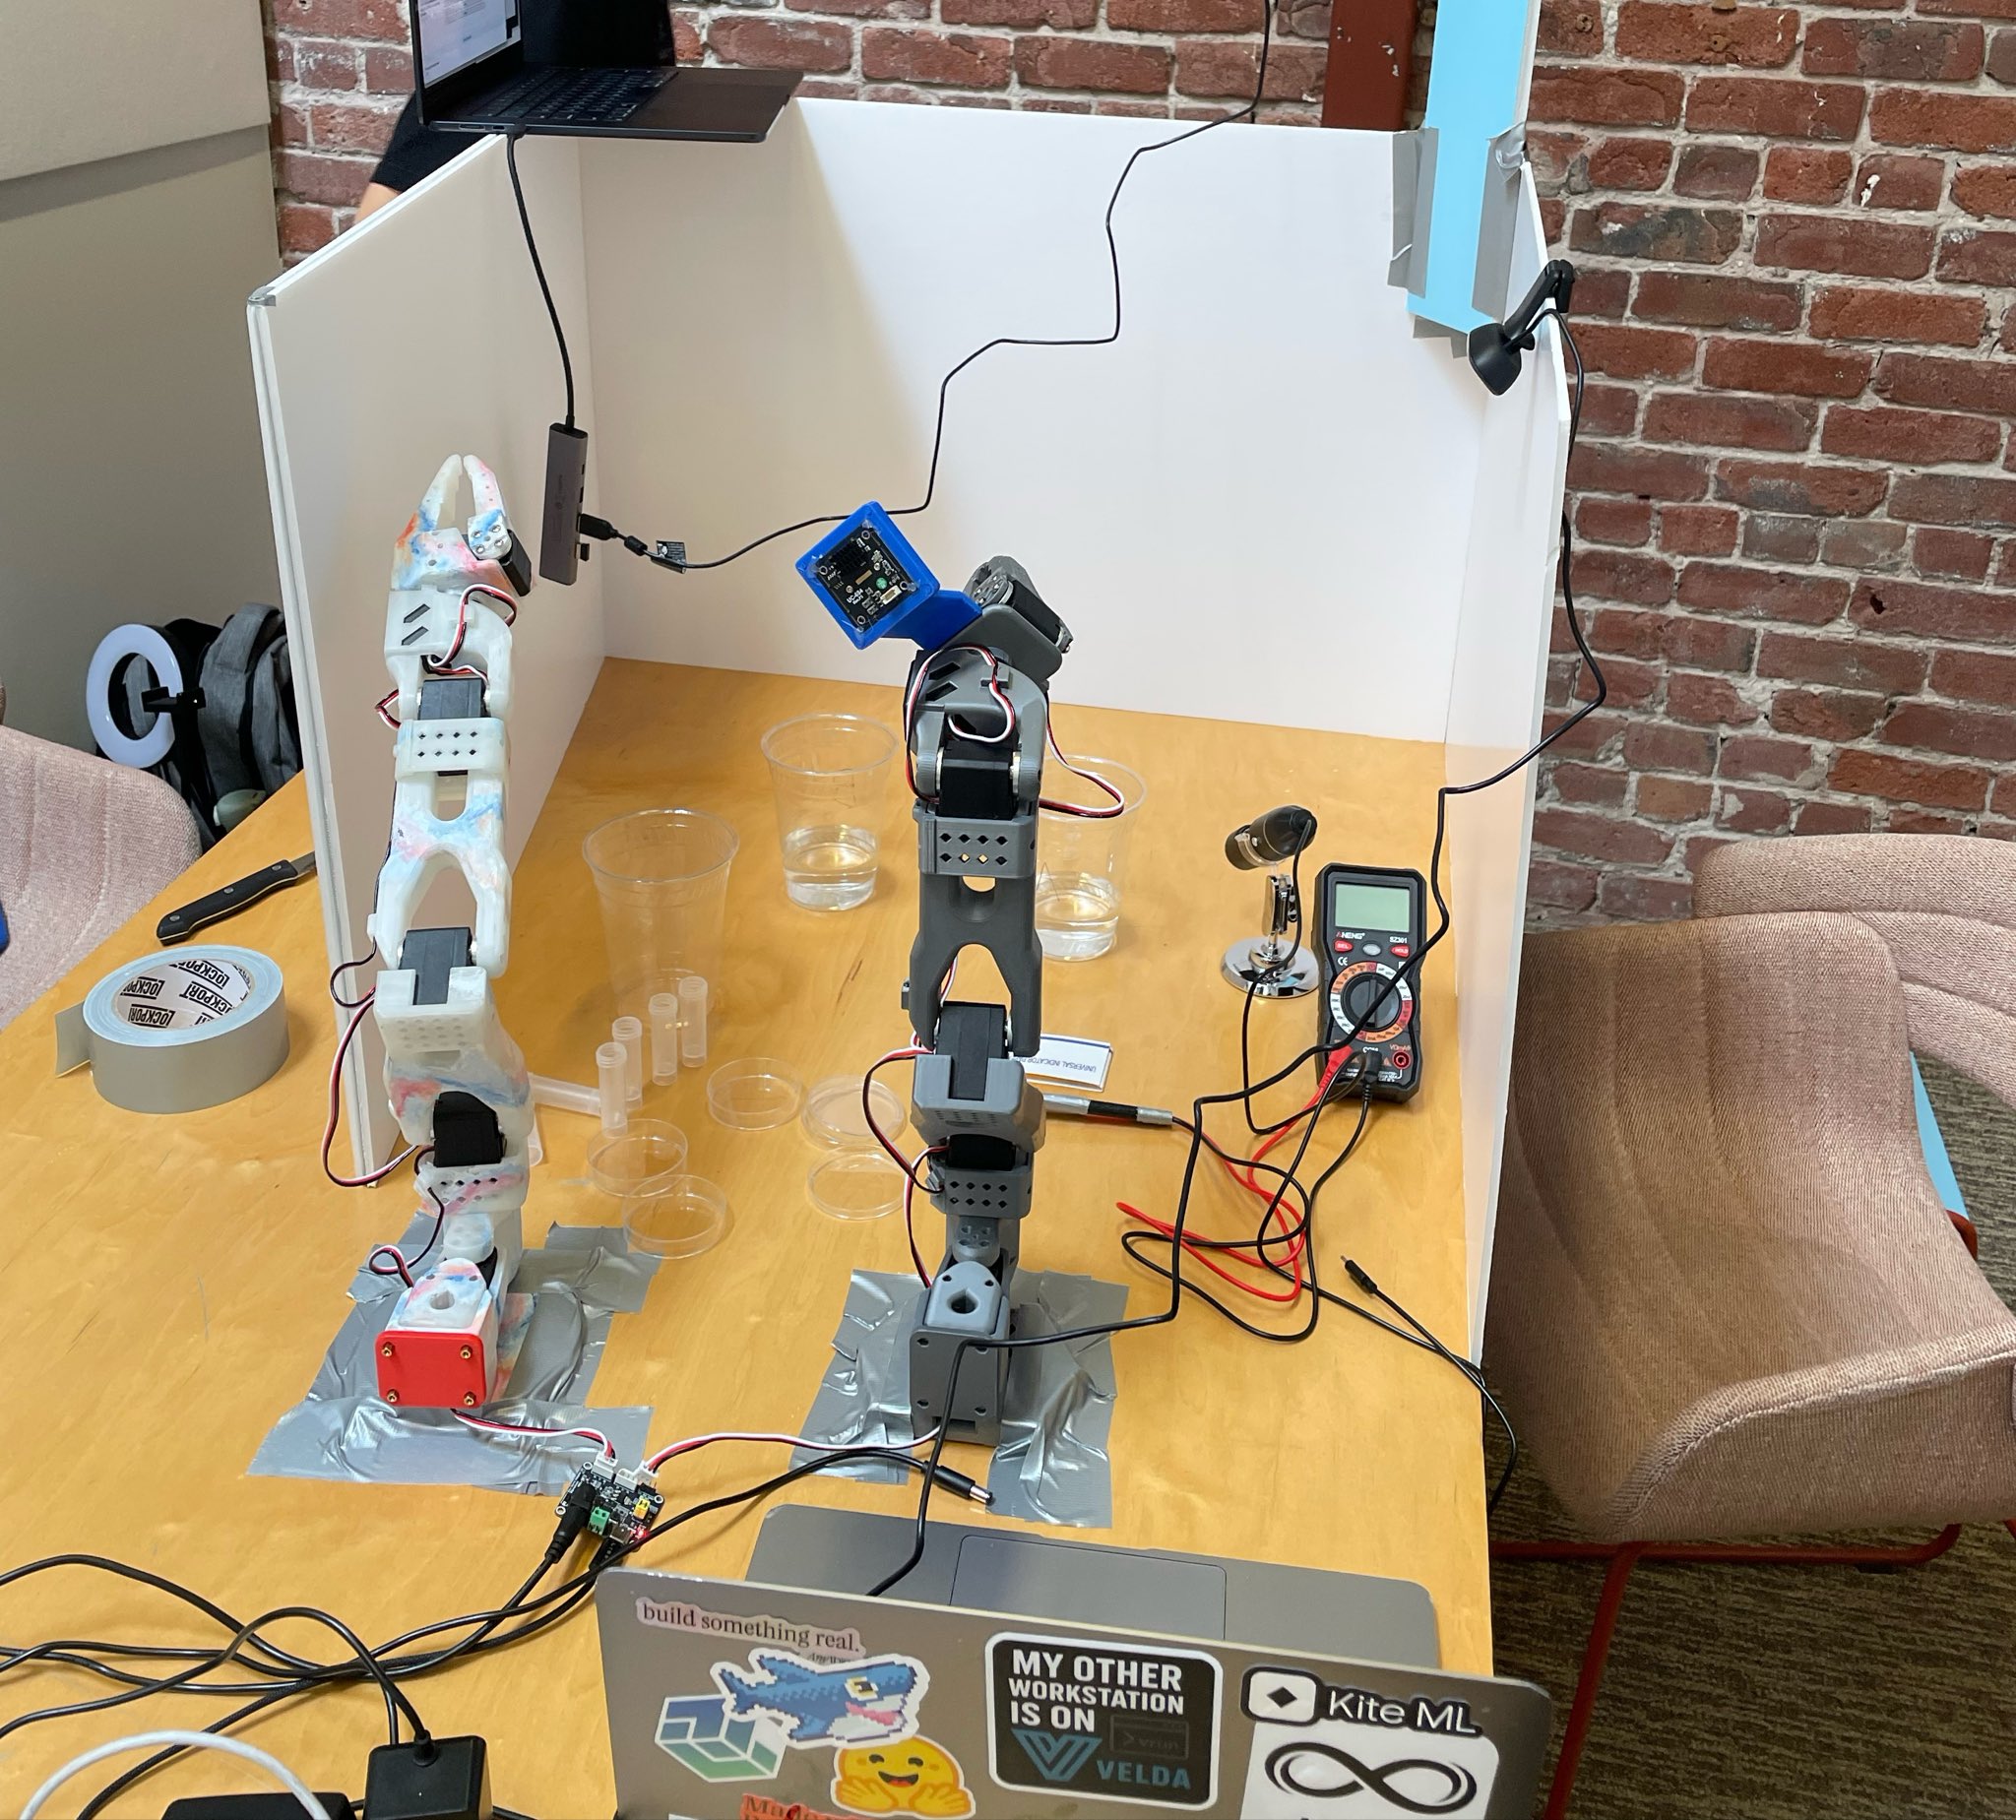
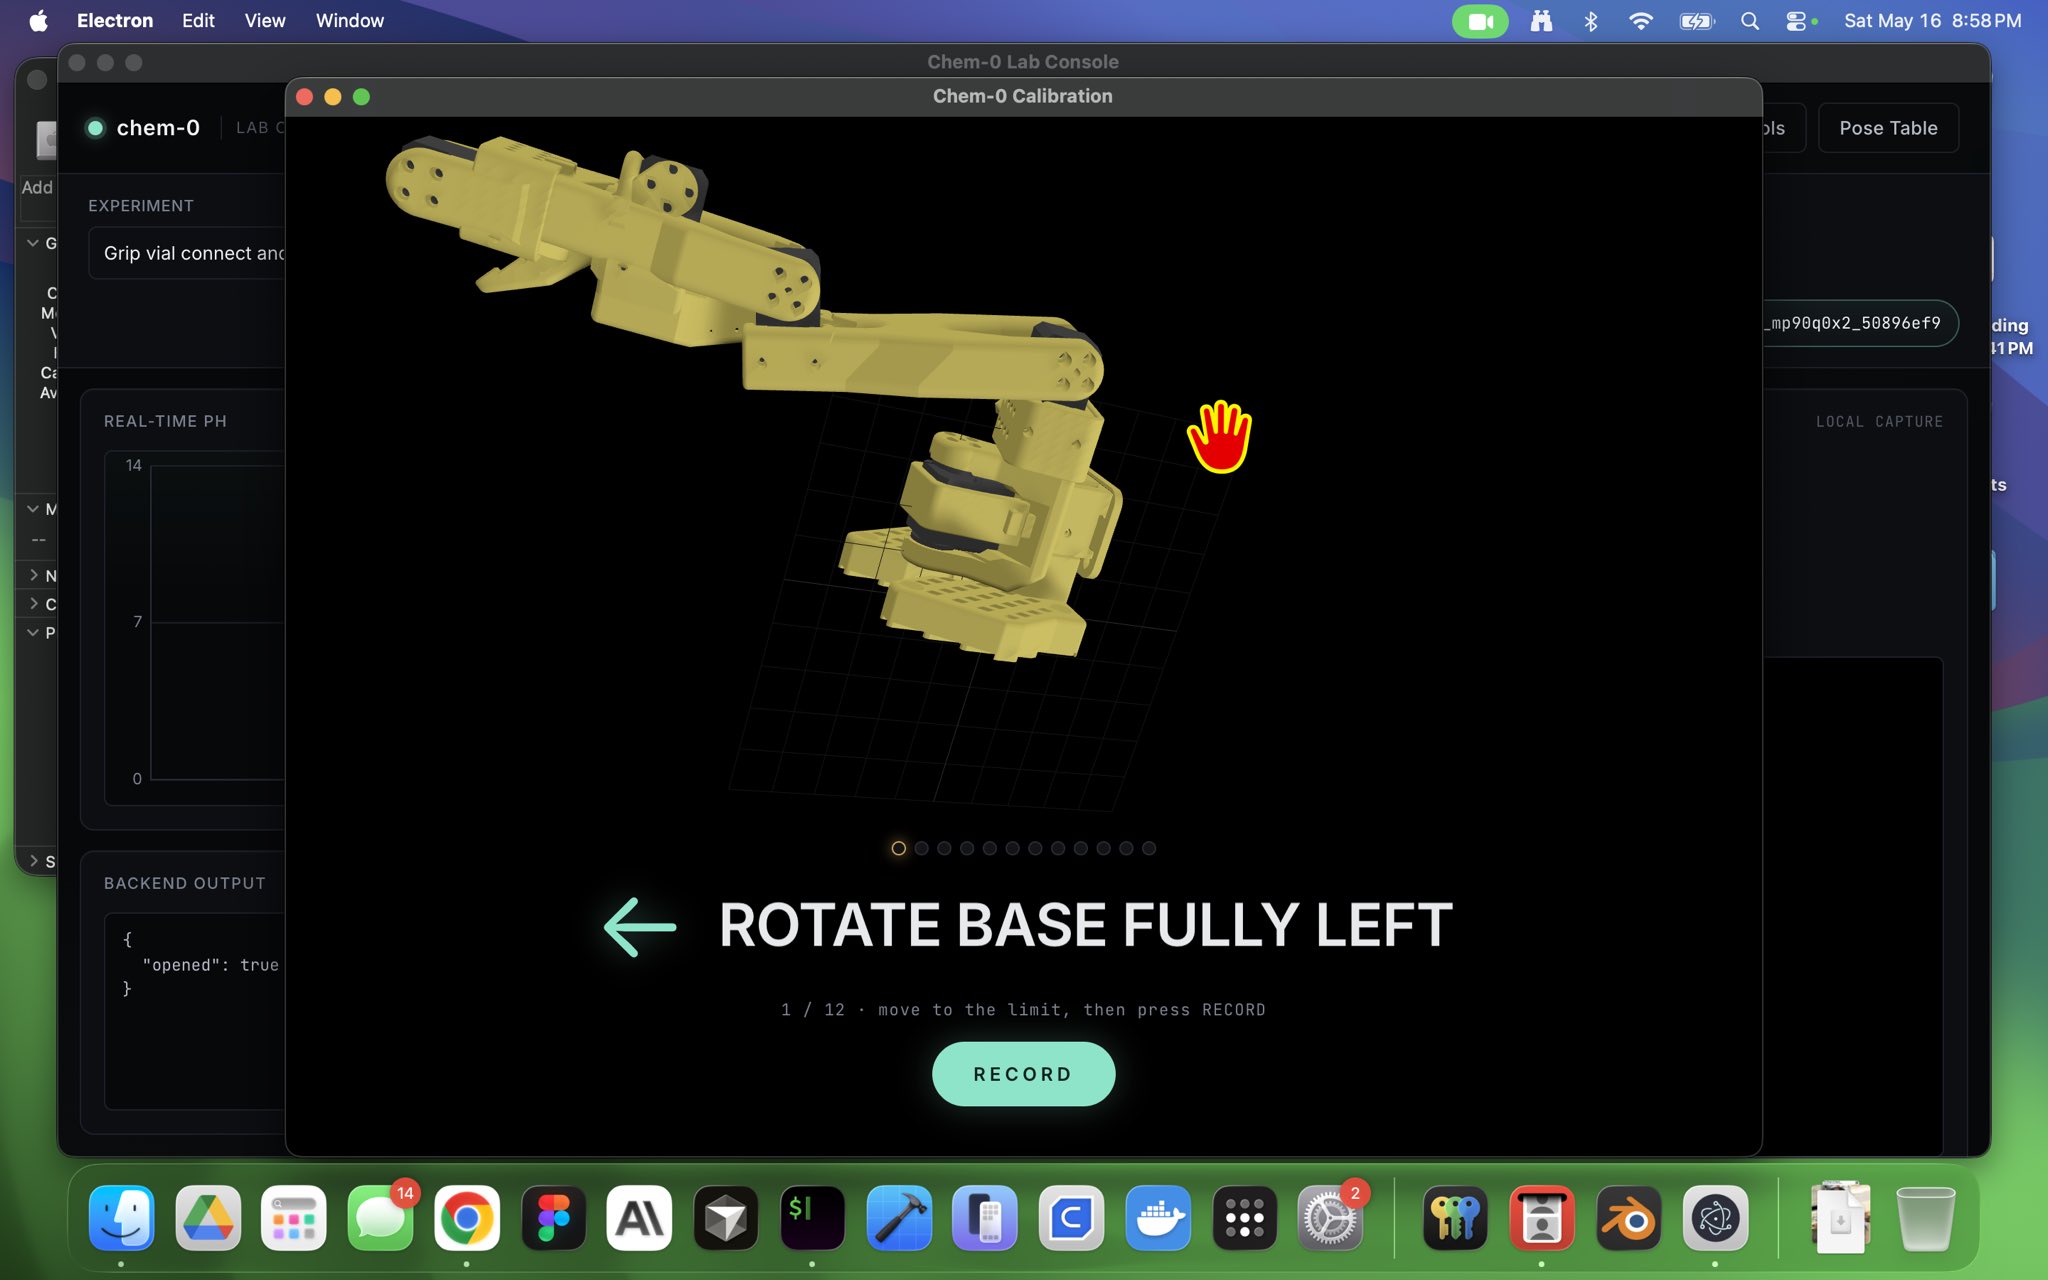
(5/5): what i want to emphasize from this weekend is that the bottleneck for embodied intelligence rn is probably not “reasoning” in the abstract
it’s calibration, instrumentation, feedback architecture, and the enormous hidden labor required to turn any unstructured region of…
Chem-0 X thread on the weekend build, the two-layer world interface, the vial-grasp failure, the simulator turn, and the calibration, instrumentation, and feedback architecture bottlenecks that showed up once the robot had to touch the physical lab bench.
Thread posts:
- https://x.com/jvboid/status/2056649613499924711?s=20
- https://x.com/jvboid/status/2056649662979887498?s=20
- https://x.com/jvboid/status/2056649673419710761?s=20
- https://x.com/jvboid/status/2056649686367588626?s=20
- https://x.com/jvboid/status/2056649696740012409?s=20
- https://x.com/jvboid/status/2056649770870226945?s=20